 TECHMECH · Wuxi Tengma precision transmission
TECHMECH
Give the servo axis a complete mechanical specification.
A compact coaxial axis and a right-angle transmission call for different shaft connections, bearing arrangements and precision grades. TECHMECH's TF and TST documents make these decisions visible. Use the frame, ratio and stage row together, then connect the gearbox selection to the motor and driven machine.
Two distinct mechanical routes
Decide where the motor can fit before choosing a ratio.
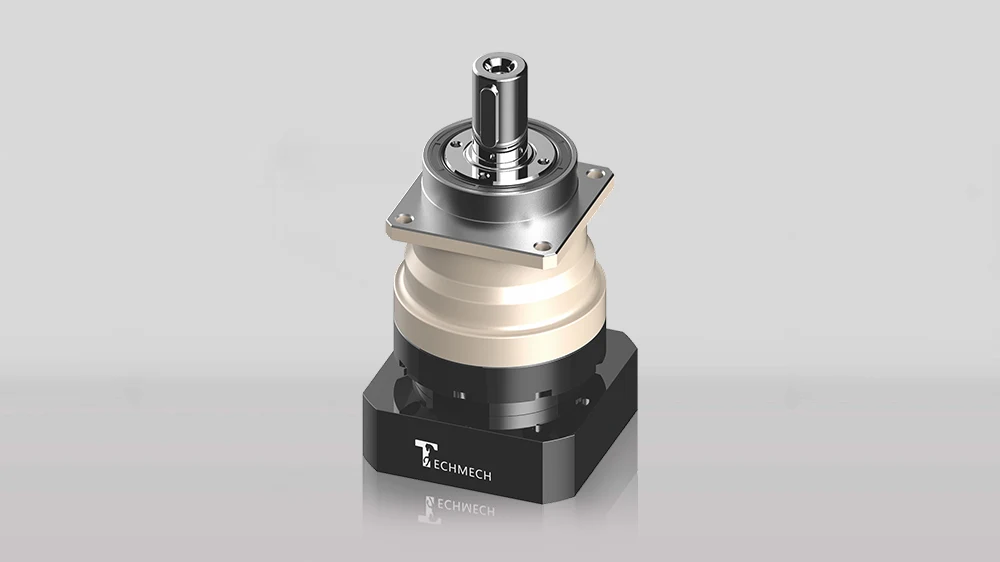
TF · coaxial servo drive
The product page describes output sizes of 60–180 mm and single- or two-stage reduction. The motor and output axis share a coaxial arrangement. Select a frame's ratio row and backlash grade, then check its motor adapter, shaft and mounting dimensions.
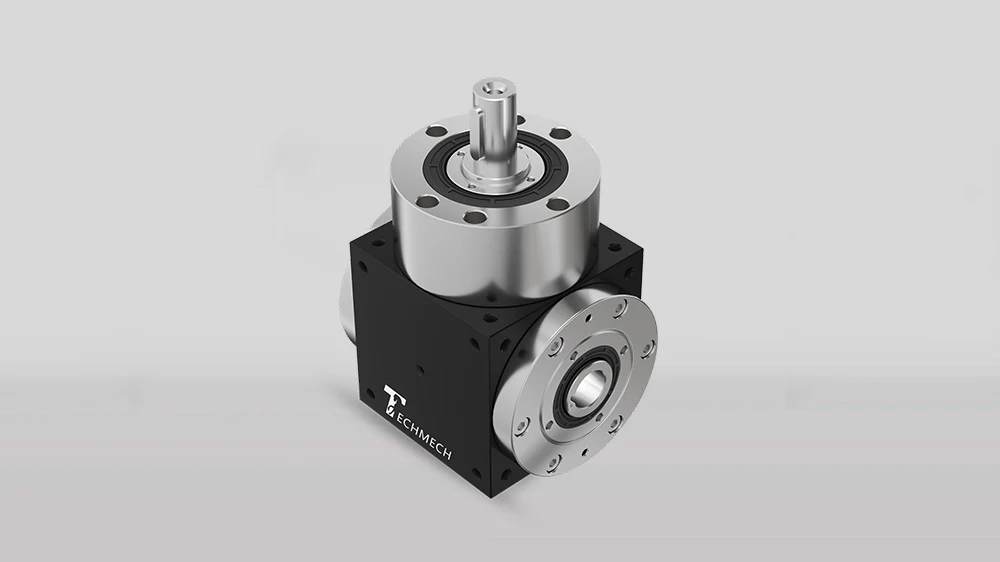
TST · turn the transmission path
The TST manual offers flange, shaft and reducer inputs; hollow, single-axis and dual-axis outputs; and two bearing forms. Its base right-angle unit and configurations with an added reduction stage have different rating and backlash tables.
TF manual · printed pages 99–100
TF075: the ratio changes the rated torque.
The examples below are read from the same frame's official performance table. They illustrate why a family maximum is insufficient for servo-axis selection.
| Configuration | Nominal output torque T₁ | Nominal / maximum input speed | Published backlash grades | Efficiency |
|---|---|---|---|---|
| TF075 · one stage · i=5 | 160 Nm | 4,000 / 8,000 rpm | P0 ≤1; P1 ≤3; P2 ≤5 arcmin | ≥97% |
| TF075 · one stage · i=10 | 102 Nm | 4,000 / 8,000 rpm | P0 ≤1; P1 ≤3; P2 ≤5 arcmin | ≥97% |
| TF075 · two stages · i=20 | 160 Nm | 4,000 / 8,000 rpm | P1 ≤5; P2 ≤7 arcmin; P0 not listed | ≥94% |
| TF075 · two stages · i=100 | 102 Nm | 4,000 / 8,000 rpm | P1 ≤5; P2 ≤7 arcmin; P0 not listed | ≥94% |
The table also gives TF075 torsional rigidity of 14 Nm/arcmin, synthetic-grease lubrication and IP65 protection. Noise is specified under a separate 3,000 rpm input, i=10 test condition. Backlash, stiffness and noise answer different questions; specify the acceptance method and operating conditions for each required result.
TST: describe the connections, not just “right-angle.”
The ordering example on printed page 153 identifies the frame, input interface, output interface, bearing form, output direction, overall ratio and precision grade. These choices determine whether the assembly can connect to your machine.
Input code
F denotes flange input, D shaft input and R reducer input. Send the actual motor pilot, bolt pattern, shaft diameter/length and coupling clearance; a motor power number does not define its interface.
Output code & direction
O denotes hollow output, S single-axis output and V dual-axis output. The drawing distinguishes left, right and bilateral output arrangements. Mark the required shaft direction and rotation on the machine drawing.
Bearing form
The manual distinguishes T tapered-roller and B deep-groove ball bearings. Give the supplier radial/axial forces, applied moment, load position and duty so the proposed support can be checked.
Added reduction
A base i=1 unit and a unit with an additional reducer are different configurations. The manual's one-stage table gives P0/P1/P2 backlash of 3/6/9 arcmin; the two-stage table gives 4/7/10 arcmin. Identify the complete assembly and grade on the quotation.
A concrete base-unit example
For TST090 at i=1, the one-stage table lists 78 Nm rated output torque, 117 Nm maximum acceleration torque and 234 Nm maximum output torque, with 3,000 rpm rated and 5,500 rpm maximum input speed. The table separately lists 3,200 N radial and 1,600 N axial allowances. These are distinct rows, not simultaneous operating limits. The manual says final parameters and dimensions are issued according to the customer's data.
Connect the gearbox rating to the complete motion axis.
Start with acceleration and load.
Provide moving mass or rotary inertia, transmission geometry, speed, acceleration, cycle time, dwell and positioning tolerance. Include gravity, process force and braking. Ask for the reflected inertia, motor torque/speed check and gearbox duty calculation.
Check adapter and external support.
Send the motor model and dimension sheet, selected shaft/key/coupling, gearbox pilot and mounting drawing. For belt, rack or cantilever loads, give the force location and independent-bearing arrangement.
Separate backlash from system accuracy.
Agree backlash grade and test procedure, then consider torsional compliance, coupling, support, encoder position and control tuning. A ≤1 arcmin gearbox row alone does not establish the accuracy of the assembled machine.
Manufacturing context · official and government sources
A Wuxi precision-transmission company in a robotics cluster.
TECHMECH's official site identifies Wuxi Tengma Precision Transmission and gives a Huishan address. It describes external-gear hard skiving and repeated internal-gear broaching as part of its production approach. For an order, request the actual gear material, heat-treatment specification, inspection records and serial traceability rather than treating a process description as a test result.
A Wuxi government article published on 19 August 2025 places Tengma in the Luoshe robotics intelligent-manufacturing park and describes its precision planetary and harmonic-reducer direction. It also discusses future expansion plans; those plans are not current delivered capacity. For a factory visit or qualification, confirm the present manufacturing location and which entity supplies the ordered assembly.
The official service section offers selection, installation guidance and reducer inspection. Define the supplied adapter/drawing scope, commissioning responsibilities, acceptance records, spare-parts identification and warranty route in the quotation.
Send a motion-axis brief with a dimension sheet.
Give TECHMECH enough information to return a frame, ratio, grade and interface that can be checked.
- Application, axis layout, quantity and installation envelope.
- Load/inertia, motion cycle, speed, acceleration and stops.
- Continuous and repeated-peak torque with duration.
- TF/TST frame, ratio, stage count and requested grade.
- Motor model, pilot, bolt pattern, shaft and adapter drawing.
- Output connection, forces, load position and support.
- Positioning requirement and agreed measurement method.
- Drawing revision, test records and delivery/service scope.
Sources & review
Reviewed 8 October 2026. Numbers are read from identified manual frames and rows. Motion-system questions are editorial selection guidance.
- TECHMECH · company and service information ↗Legal identity, location and supplier production/service descriptions.
- TECHMECH · TF product page ↗Coaxial family description and official product illustration.
- TECHMECH · TF manual, printed pages 99–100 ↗TF075 ratio-specific nominal torque, speed, backlash, force and test-condition rows.
- TECHMECH · TST product page ↗Right-angle family information and official illustration.
- TECHMECH · TST manual, printed pages 153–156 ↗Ordering codes, one/two-stage rating tables and connection drawings.
- Wuxi government · robotics industrial-cluster report ↗Company's manufacturing-cluster context and development direction.
 LinkedIn
 X
 Facebook
 WhatsApp
 Telegram
 Reddit
 Email