 SWT · robot-joint RV transmission
SWT precision reducers
Choose the joint architecture before the torque.
Hubei SWT Transmission develops two-stage RV reducers in Wuhan. Its SZ(N) catalogue addresses compact coaxial robot joints, while K(C) provides a hollow passage for routing services. Compare a defined output-speed rating, the assembly interfaces and the joint’s external loads together.
Compact coaxial joint or a hollow service passage?
Both use a first-stage gear reduction followed by cycloidal reduction. Their intended integration differs. These examples are bare reducers, not complete servo joints with motor, encoder, brake and controller.
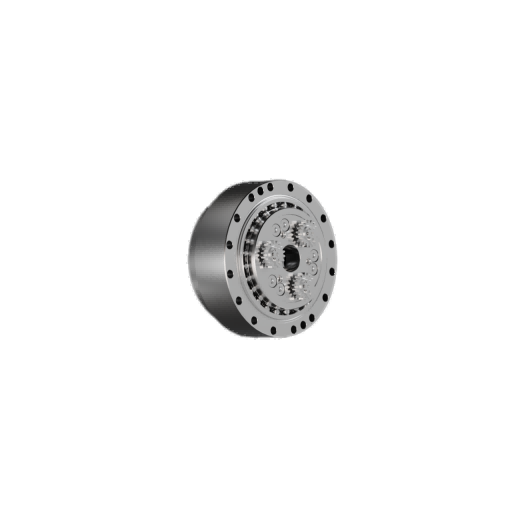
07SZ · compact coaxial SZ(N)
The manufacturer describes SZ as an upgrade of S, with coaxial input/output and flexible configurations for lightweight robot joints. The 07SZ introduction gives 42 Nm at 30 rpm, 1.8 kg mass, allowable thrust of 1,200 N and backlash no greater than 1 arcmin.
The ratio table distinguishes shaft rotation (31, 49, 68.5, 88, 101) from housing rotation (30, 48, 67.5, 87, 100). Select the rotation arrangement before specifying the ratio.
07SZ dimensions and official tables →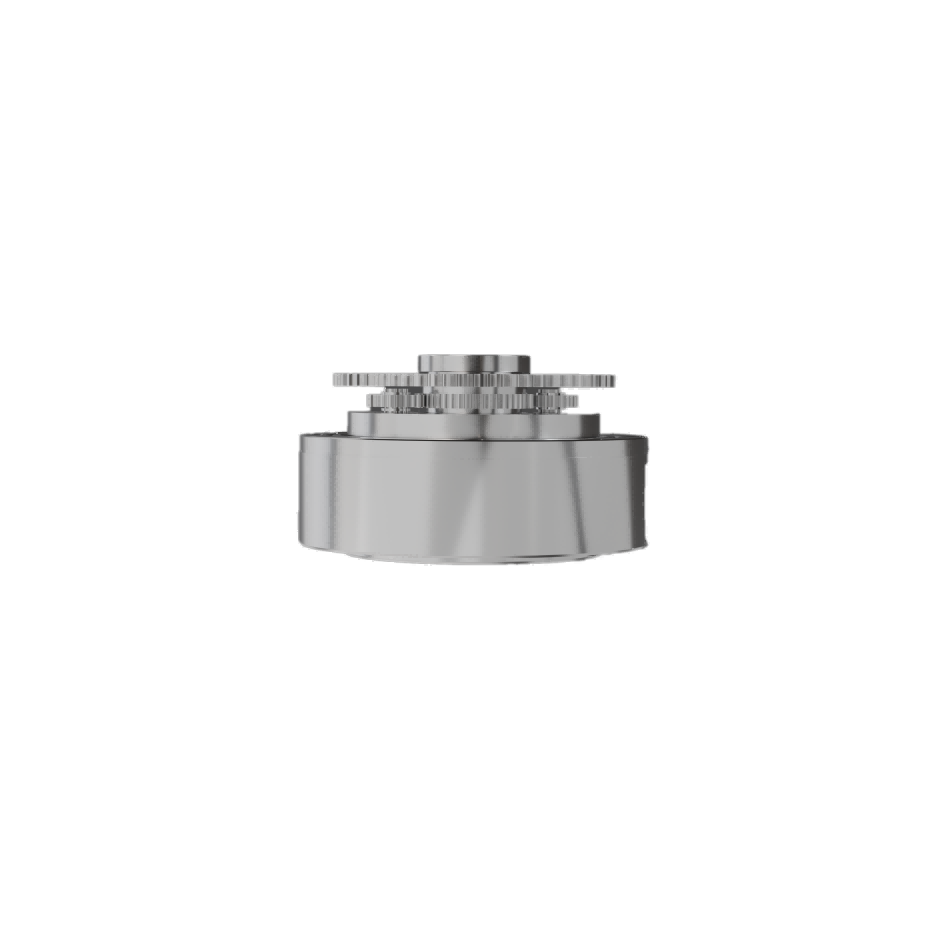
10K · hollow K(C)
The K description provides a central passage and identifies robot base/fourth-axis, welding-positioner and column-palletizer applications. The bare 10K introduction gives 98 Nm at 15 rpm, 4.6 kg mass, allowable thrust of 5,880 N and backlash no greater than 1 arcmin.
The table’s R1 = 27 is the reducer-unit ratio. Total reduction depends on the centre/input gear arrangement; it is not automatically the complete motor-to-output ratio.
10K hollow arrangement and drawings →The catalogues also list an allowable moment: 170 Nm for 07SZ and 686 Nm for 10K. These figures belong to the external loading assessment, not the rated drive-torque column. Supply the tool mass, centre of gravity and load direction so the supplier can calculate the combined moment/thrust limits.
One 10K model, four different operating points.
The official bare-unit table relates output torque and input power to output speed. This extract shows why a joint cannot be selected from a single headline torque.
| Model / unit ratio | Output speed | Published output torque | Published input power |
|---|---|---|---|
| 10K / R1 = 27 | 5 rpm | 136 Nm | 0.09 kW |
| 10K / R1 = 27 | 15 rpm | 98 Nm | 0.21 kW |
| 10K / R1 = 27 | 30 rpm | 80 Nm | 0.34 kW |
| 10K / R1 = 27 | 60 rpm | 65 Nm | 0.54 kW |
These are supplier table values, not independent measurements. The page separately lists 245 Nm allowable start/stop torque and 490 Nm instantaneous maximum torque. Neither substitutes for the running rating. Ask for permitted duration, repetitions and the life calculation against your actual motion cycle.
The advertised 1 arcmin backlash is a component statement. A robot’s tool-point accuracy also depends on compliance, links, bearings, encoder/control behaviour and calibration. Request the test load, direction reversal, temperature and measurement method rather than treating backlash as guaranteed machine accuracy.
A bare reducer leaves real integration work.
Input gear and flange
SWT offers different input flange arrangements. The 10K page lists vertical and 90-degree integrated options and separate 60F/80F motor-interface drawings. A matching nominal flange size alone does not settle the shaft diameter, keyway, pilot diameter, bolt spacing or centre-gear ratio.
Seals and fasteners
Both detail pages say O-rings and mounting fasteners are supplied by the customer. Include seal groove dimensions, bolt grade and tightening requirements in the assembly review. The supplier warns that dimensions may change with upgrades; obtain the controlled drawing revision for the ordered unit.
Grease and orientation
The instructions state the reducer is not filled with grease at dispatch. Fill quantity depends on the mounting orientation and assembly spaces. The stated standard replacement interval is 2,000 hours; above 40°C surface temperature the instructions call for checking grease condition and shortening the interval. Agree the grease grade and current model-specific procedure before commissioning.
For a hollow K joint, describe cable/hose routing, connector clearance, rotation range and any rotary union. For SZ, describe whether the shaft or housing rotates. In both cases provide the joint bearings and load path: a reducer comparison cannot establish which surrounding structure carries the tool’s overturning moment.
Independent reporting concerns a different, heavy-load project.
A 24 November 2024 report on the Wuhan municipal government website, sourced to Changjiang Daily, names Hubei SWT Transmission in an RV-reducer order for fusion-maintenance robotic arms. It corroborates the company’s activity in that project; it is not a test certificate for the compact 07SZ or hollow 10K above.
The official company page describes gear-grinding equipment and in-process inspection. For an automation order, request the lot-specific acceptance records, traceable model/revision and agreed measurement criteria. Historical company awards or predecessor certificates should not be substituted for current documents held by the contracting company.
Prepare a robot-joint brief.
Start with the joint layout and motion cycle. Then ask SWT for a particular reducer configuration and its current drawing.
Save this manufacturer to include it in your enquiry.- Joint function, shaft/housing rotation, hollow routing needs and installation envelope.
- Output-speed profile, running torque, acceleration peaks, emergency-stop load and cycle frequency.
- Tool mass, centre of gravity, allowable thrust/moment and surrounding bearing arrangement.
- Motor shaft/flange drawing, input gears, required total ratio, brake and encoder interfaces.
- Backlash acceptance method, target life, grease procedure, controlled drawing revision and quantity.
Sources & review
Model ratings remain separated by speed and load type. Product images and the SWT logo originate on the manufacturer’s website. Reviewed 9 October 2026.
- Official company introduction ↗Legal identity, sites, current-company history and described equipment.
- 07SZ bare-unit detail ↗Official image, shaft/housing ratios, rated point and integration instructions.
- 10K bare-unit detail ↗Official image, speed/torque/power table, distinct load limits and motor-interface drawings.
- Wuhan municipal website · 2024 project report ↗Independent company/project context, not approval of the two catalogue models.
 LinkedIn
 X
 Facebook
 WhatsApp
 Telegram
 Reddit
 Email